Within the Control Systems Department, we model the rocket’s dynamics and behavior using Simulink. We develop the active control system to precisely track the rocket’s desired trajectory, simulating the response of the active control surfaces and adjusting the response of the airbrakes to ensure optimal performance, allowing the rocket to accurately handle unexpected deviations from the assumed flight trajectory. Finally, we manage the rocket’s navigation system by implementing a Kalman Filter, through which we derive the rocket’s exact flight conditions in real time by filtering the data received from the onboard sensors.
Topics
ACTIVE CONTROL SYSTEMS FOR AIRBRAKES
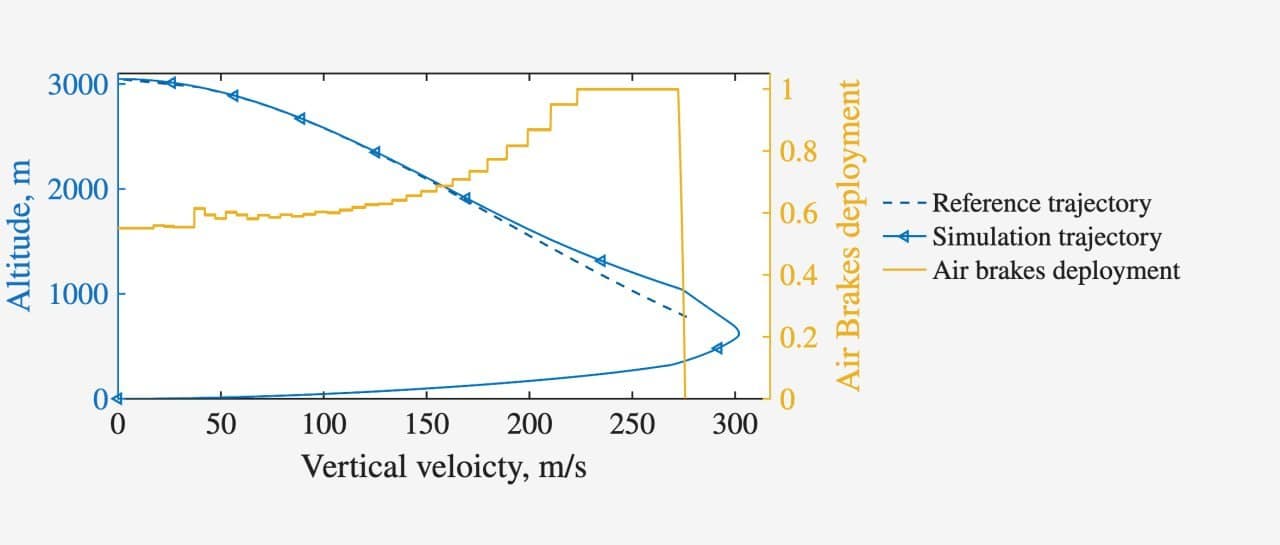
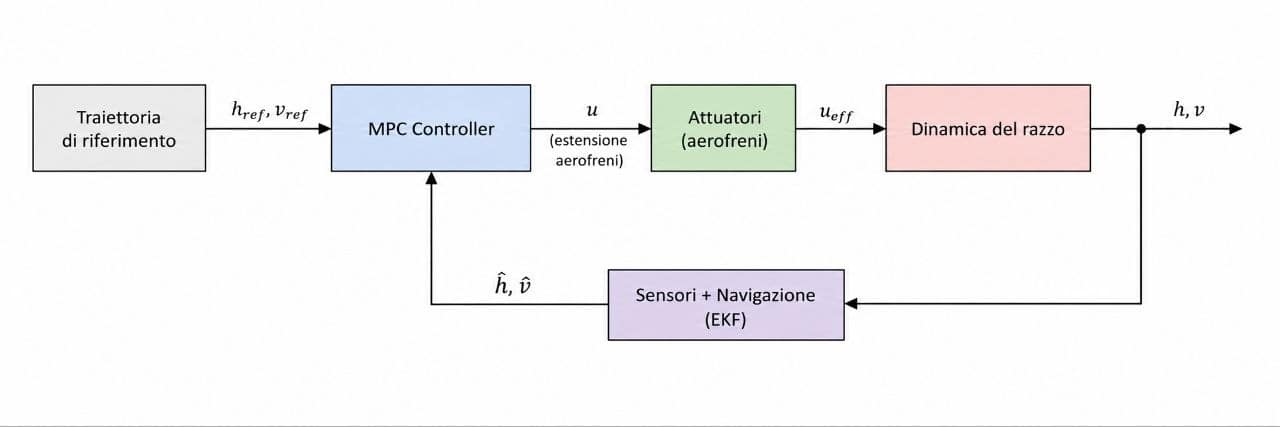
The rocket’s active control system uses airbrakes to adjust the trajectory during the coast phase and precisely reach the desired apogee. The controller, developed in MATLAB/Simulink, is based on a Model Predictive Control (MPC) strategy: during flight, the system uses real-time estimates of altitude and vertical velocity to predict the future evolution of the trajectory by solving an optimal control problem at each control cycle, thereby determining the optimal airbrake extension in relation to the rocket’s dynamics and the actuators’ physical limits. At each cycle, only the first command of the optimized sequence is applied (receding horizon): this allows the system to continuously correct the trajectory and adapt to changes in flight conditions and model uncertainties. The algorithm is designed to run on the onboard avionics at a frequency of 6 Hz and is validated through Model-in-the-Loop and Hardware-in-the-Loop simulations, as well as Monte Carlo analysis, in order to verify its accuracy and robustness under various operating conditions.
KALMAN FILTER
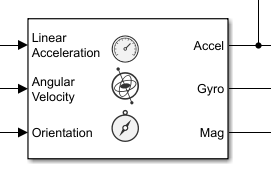
The navigation system is the fundamental basis on which all the rocket’s other control systems operate and rely, with the critical task of determining the vehicle’s attitude and kinematic state in real time and with extreme precision. Developed in MATLAB, the algorithm is based on a Multiplicative Extended Kalman Filter (MEKF). The system continuously fuses high-frequency IMU readings with barometer and GNSS module data, enabling the propagation of a complete three-dimensional state vector. To handle the complexity of a real vehicle, a sequential-update architecture has been implemented that optimizes computational load and efficiently manages asynchronous sensor measurements, while process noise is dynamically adapted during flight, as is the weighting of individual measurements. Pre-flight calibration logic is also integrated to neutralize inertial drift on the pad. Optimized for C++ code generation and execution on the onboard avionics, the algorithm is validated through Model-in-the-Loop and Hardware-in-the-Loop simulations and Monte Carlo analysis to certify its absolute robustness.
SIMULATIONS: SITL AND HITL
Software-in-the-Loop (SITL) and Hardware-in-the-Loop (HITL) simulations are fundamental to our development approach. SITL simulations enable rapid prototyping, allowing us to iteratively refine controller gains and validate control strategies in a virtual environment. These simulations are crucial for evaluating how our control algorithms respond to disturbances, letting us fine-tune and optimize our strategies. In addition to SITL simulations, HITL simulations bridge the gap between the virtual and the physical, enabling the evaluation of controller responses using real rocket hardware. This method allows us to further test, validate, and optimize our control strategies by assessing their performance in a real-world context, ensuring robustness and reliability in our control mechanisms.
WANT TO JOIN? THIS IS WHAT WE ARE LOOKING FOR:
REQUIRED SKILLS:
Proficiency in MatLab and Simulink.
Basic knowledge of writing in LaTeX.
Willingness to push beyond one’s own limits.
Ability to self-organize one’s work.
ADVANCED SKILLS:
Control Systems Theory.
Theory of optimal control problems / NLP.
Kalman Filtering theory.
Knowledge of a programming language (C++ or Python).